Egocentric Vision and Embodied AI Lab · Ulm University

Seeing the world from a first-person perspective

Our research connects egocentric vision with embodied AI, from understanding human intent in first-person video to world models and robots that reason and manipulate.

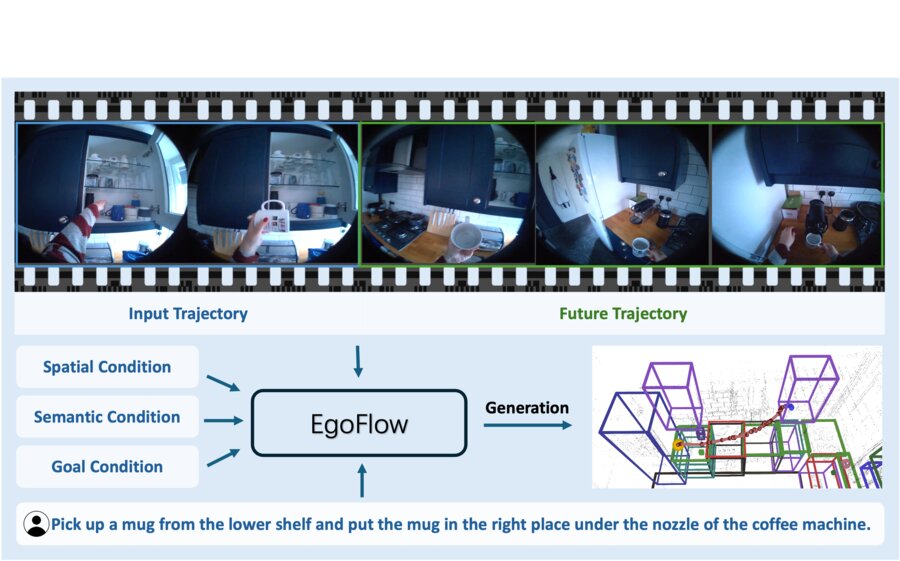
Egocentric video frames and predicted object motion from the EgoFlow paper
EgoFlow, CVPR 2026

News

Latest from the lab

All news
  • Nikita Tatsch and Denys Nartsev join the lab

    Nikita Tatsch and Denys Nartsev join the group as PhD students. Welcome!

  • The Ego-AI Lab starts at Ulm University

    We are excited to push forward in the exciting fields of Egocentric Vision and Embodied AI.

Publications

Selected work

All publications

EgoFlow: Gradient-Guided Flow Matching for Egocentric 6DoF Object Motion Generation

Abhishek Saroha, Huajian Zeng, Xingxing Zuo, Daniel Cremers, Xi Wang

CVPR 2026 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR)

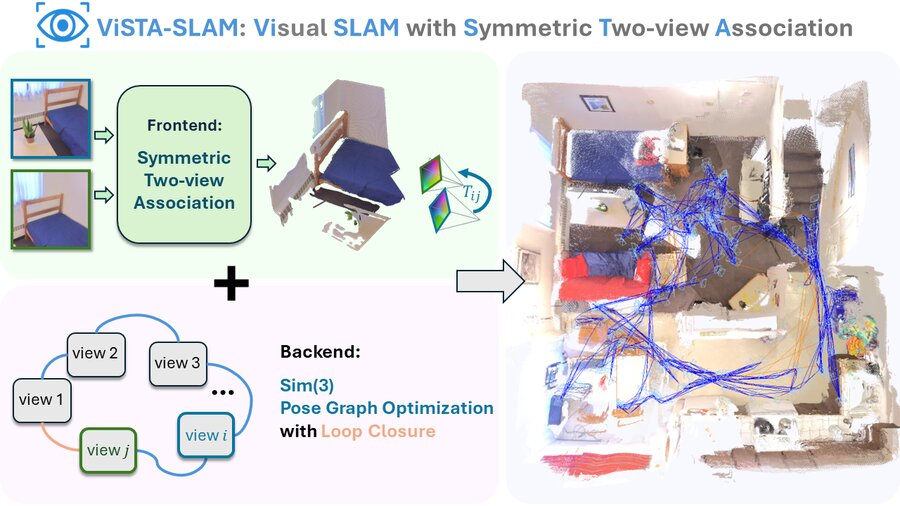
ViSTA-SLAM: Visual SLAM with Symmetric Two-view Association

Ganlin Zhang, Shenhan Qian, Xi Wang, Daniel Cremers

3DV 2026 International Conference on 3D Vision (3DV)

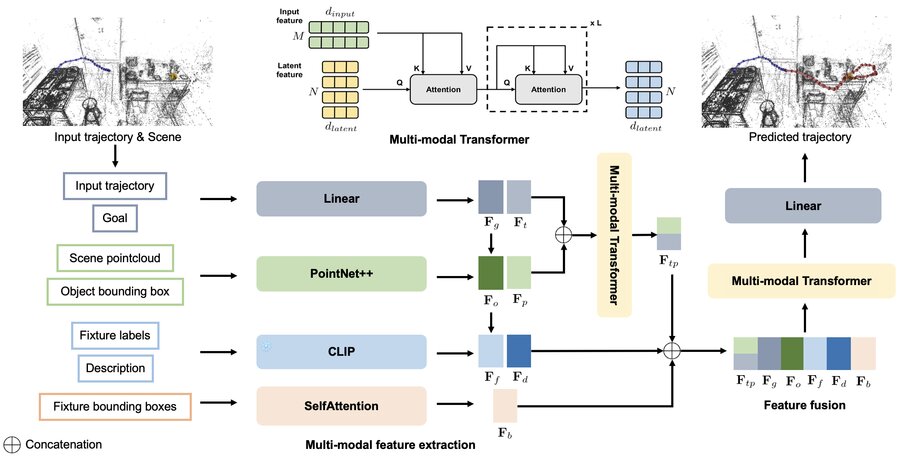
GMT: Goal-Conditioned Multimodal Transformer for 6-DOF Object Trajectory Synthesis in 3D Scenes

Huajian Zeng*, Abhishek Saroha*, Daniel Cremers, Xi Wang

3DV 2026 International Conference on 3D Vision (3DV)

* equal contribution